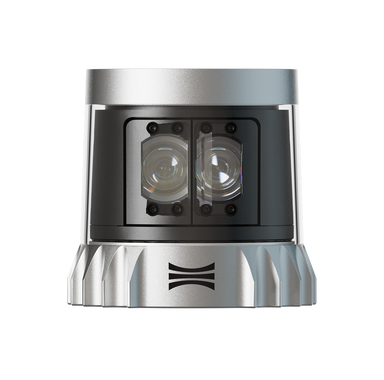
Fortran's Ouster listing brings together lidar sensor and BlueCity product information for traffic detection and data-collection projects. The catalogue includes OS1, OS2 and OSMAX Rev8 listings alongside BlueCity. These entries cover different products and hardware generations, so the required sensing and reporting functions should guide the initial comparison.
A sensor specification and a wider traffic analytics arrangement are different parts of a project. Identify the road users, movements and information that need to be measured, then review the exact sensor revision and associated software or processing equipment. Range, resolution and interface values should be taken from the document for the proposed hardware rather than transferred between Ouster models or generations.
For an enquiry, provide a site plan, possible sensor positions and the required data outputs. Include existing controllers, communications equipment and reporting systems that must remain connected. Fortran can help identify the relevant product documents and the compatibility or coverage details that need confirmation before a particular configuration is selected.
Explore BlueCity information · Browse traffic data collection products · Discuss an Ouster project